Red-black trees and AVL trees are the two classic self-balancing binary search trees. Both guarantee O(log n) search, insertion and deletion, but they balance themselves with different rules, which leads to different trade-offs between lookup speed and update cost. This page recaps each tree and then compares them.
Introduction to Red-Black Tree
A red-black tree is a binary search tree in which every node carries one extra bit, its colour (red or black). Simple colouring rules keep the tree roughly balanced, and violations caused by an update are fixed with recolouring and a few rotations.
The idea goes back to Rudolf Bayer's symmetric binary B-trees (1972); the red-black formulation was introduced by Leonidas Guibas and Robert Sedgewick in 1978.
Properties of Red Black Tree
It is a binary search tree.
Every node is red or black.
The root is black.
Every NIL (empty) leaf is black.
A red node never has a red child.
For every node, all paths down to its NIL leaves contain the same number of black nodes.
Example of a Red-Black Tree
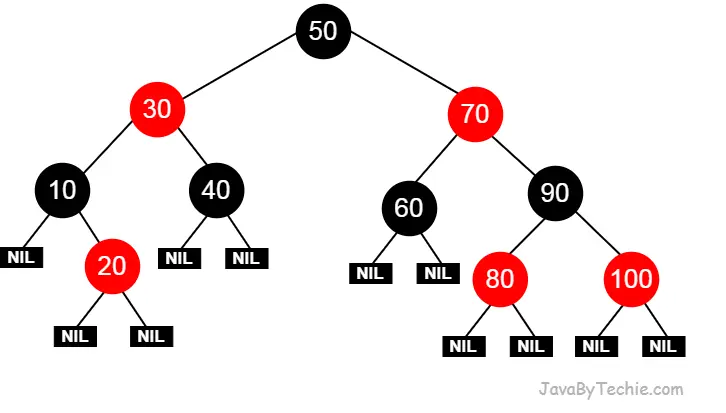
The tree above satisfies all the rules: the root is black, no red node has a red child, and every root-to-leaf path passes through the same number of black nodes.
Introduction to AVL Tree
An AVL tree is a binary search tree in which, at every node, the heights of the left and right subtrees differ by at most 1. It was published in 1962 by Georgy Adelson-Velsky and Evgenii Landis and was the first self-balancing BST.
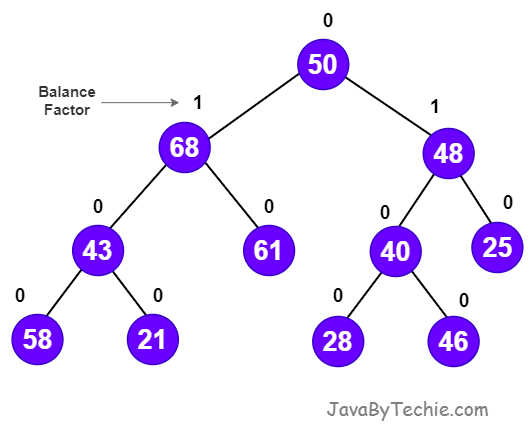
Each node keeps a balance factor, computed here as
Balance factor = height(left subtree) − height(right subtree)
which must always be −1, 0 or +1. When an update pushes it to ±2, a single or double rotation restores the balance.
Difference between Red-Black Tree and AVL Tree
Both trees are balanced, but the AVL tree is balanced more strictly. That makes its searches a little faster and its updates a little more expensive:
| Feature | Red-Black Tree | AVL Tree |
|---|---|---|
| Balance rule | No red node has a red child, and every path from a node to its NIL leaves has the same number of black nodes. | At every node, the heights of the two subtrees differ by at most 1. |
| Maximum height | About 2 log2(n + 1). | About 1.44 log2 n (stricter balance). |
| Search | O(log n); slightly more steps on average. | O(log n); slightly fewer steps. |
| Insertion | O(log n); at most 2 rotations plus recolouring. | O(log n); at most one single or double rotation. |
| Deletion | O(log n); at most 3 rotations plus recolouring. | O(log n); may need rotations at several levels on the way up. |
| Extra data per node | One colour bit. | Height or balance factor (−1, 0, +1). |
| Best suited for | Update-heavy workloads and general-purpose libraries (Java TreeMap, TreeSet). | Lookup-heavy workloads where data changes rarely. |